Building the data infrastructure for physical intelligence.
The human world is the training set. We capture high-fidelity human motion and interaction in the real world — and turn it into robot-ready data.
Modality
Full-body · Hands · Ego
Signal
6-DoF trajectories
Environment
Unconstrained, in the wild
Team
Three Stanford graduates
Language models had the internet. Robots have almost nothing.
Physical intelligence is bottlenecked by data, not architecture. Robot learning needs enormous quantities of high-quality real-world interaction — captured with human dexterity, at human scale, in unconstrained environments.
Trillions of tokens
Scraped, cheap, effectively unlimited.
Orders of magnitude short
Teleoperation is slow, costly and lab-bound.
Continuous, everywhere
Every hand, every day — currently uncaptured.
Wearable hardware that turns a person into a capture rig.
Head-mounted
Tracking gloves
Wearable cuffs
Mobile capture
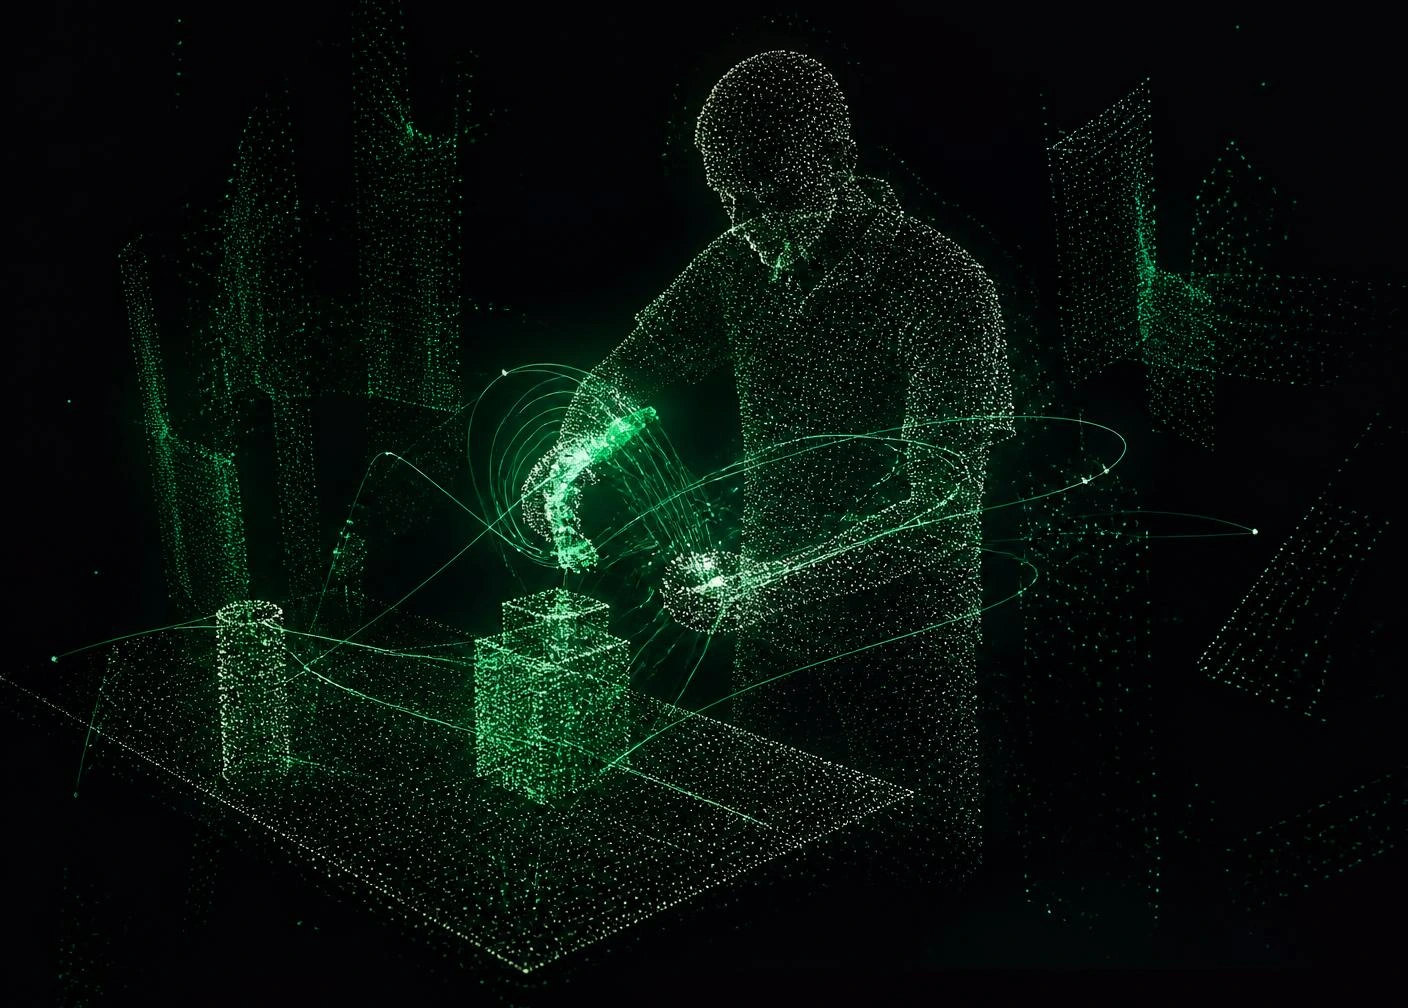
Human movement → structured motion data → robot training.
01. Human
A person performs an ordinary real-world task.
02. Tracked skeleton
Joints, fingers and 6-DoF trajectories are resolved in real time.
03. Structured data
Motion becomes aligned, machine-readable interaction sequences.
04. Robot
Sequences train policies for humanoids and manipulation systems.